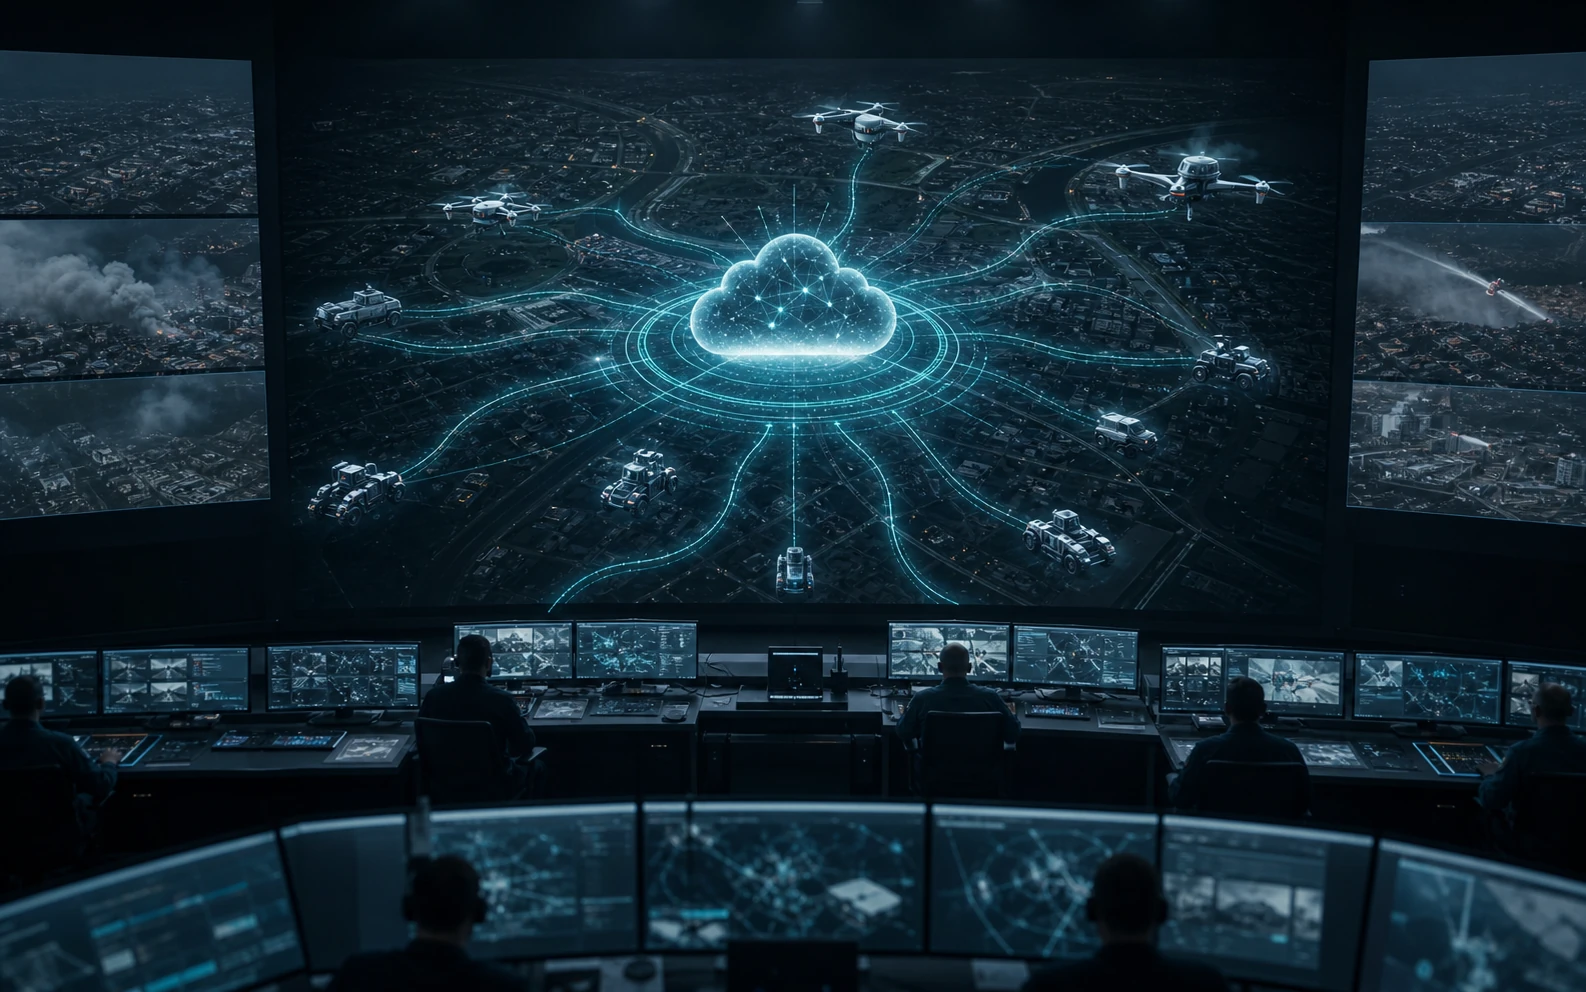
CCLOUD
Ground Command Platform
Unifies mission understanding, intelligent teaming, resource scheduling and execution monitoring.
 Global-Matrix
G-MATRIX / AI COMMAND SYSTEM
G-Matrix
G-Matrix unifies mission understanding, robot teaming, route planning, safety validation and execution monitoring in one closed loop—moving operators from device-by-device control to mission-level command.
MISSION-LEVEL COMMAND
Commanders define the objective. G-Matrix organizes robots, plans the response and keeps adapting as conditions change.
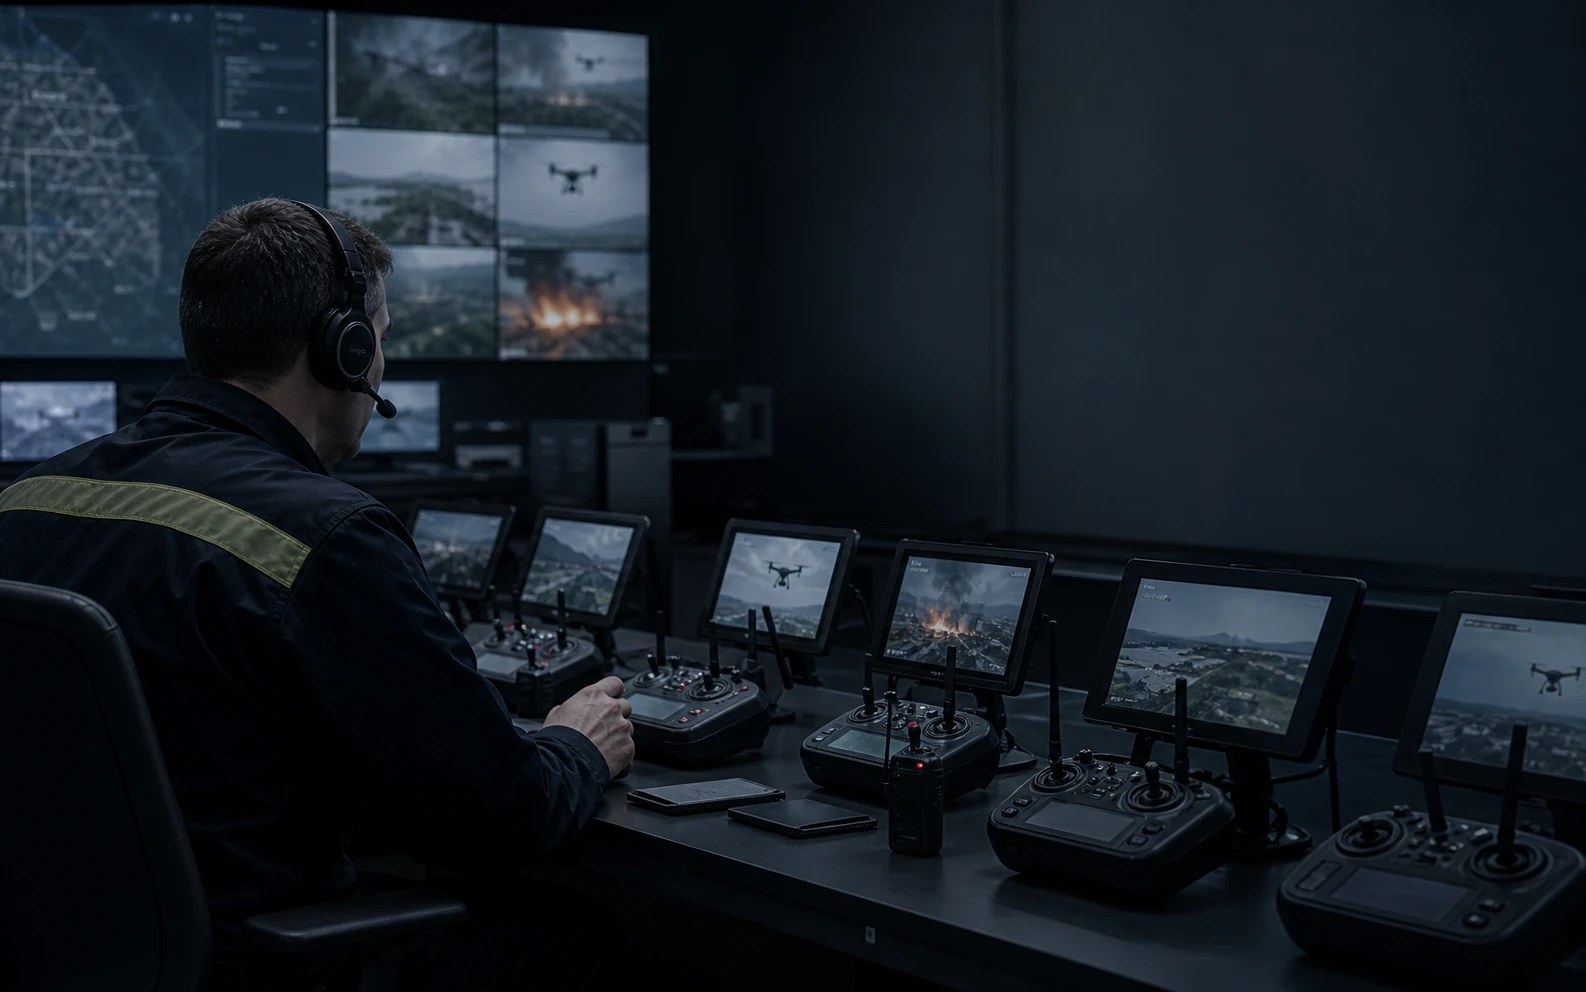
Operators select devices, connect controllers and repeat commands for every unit.
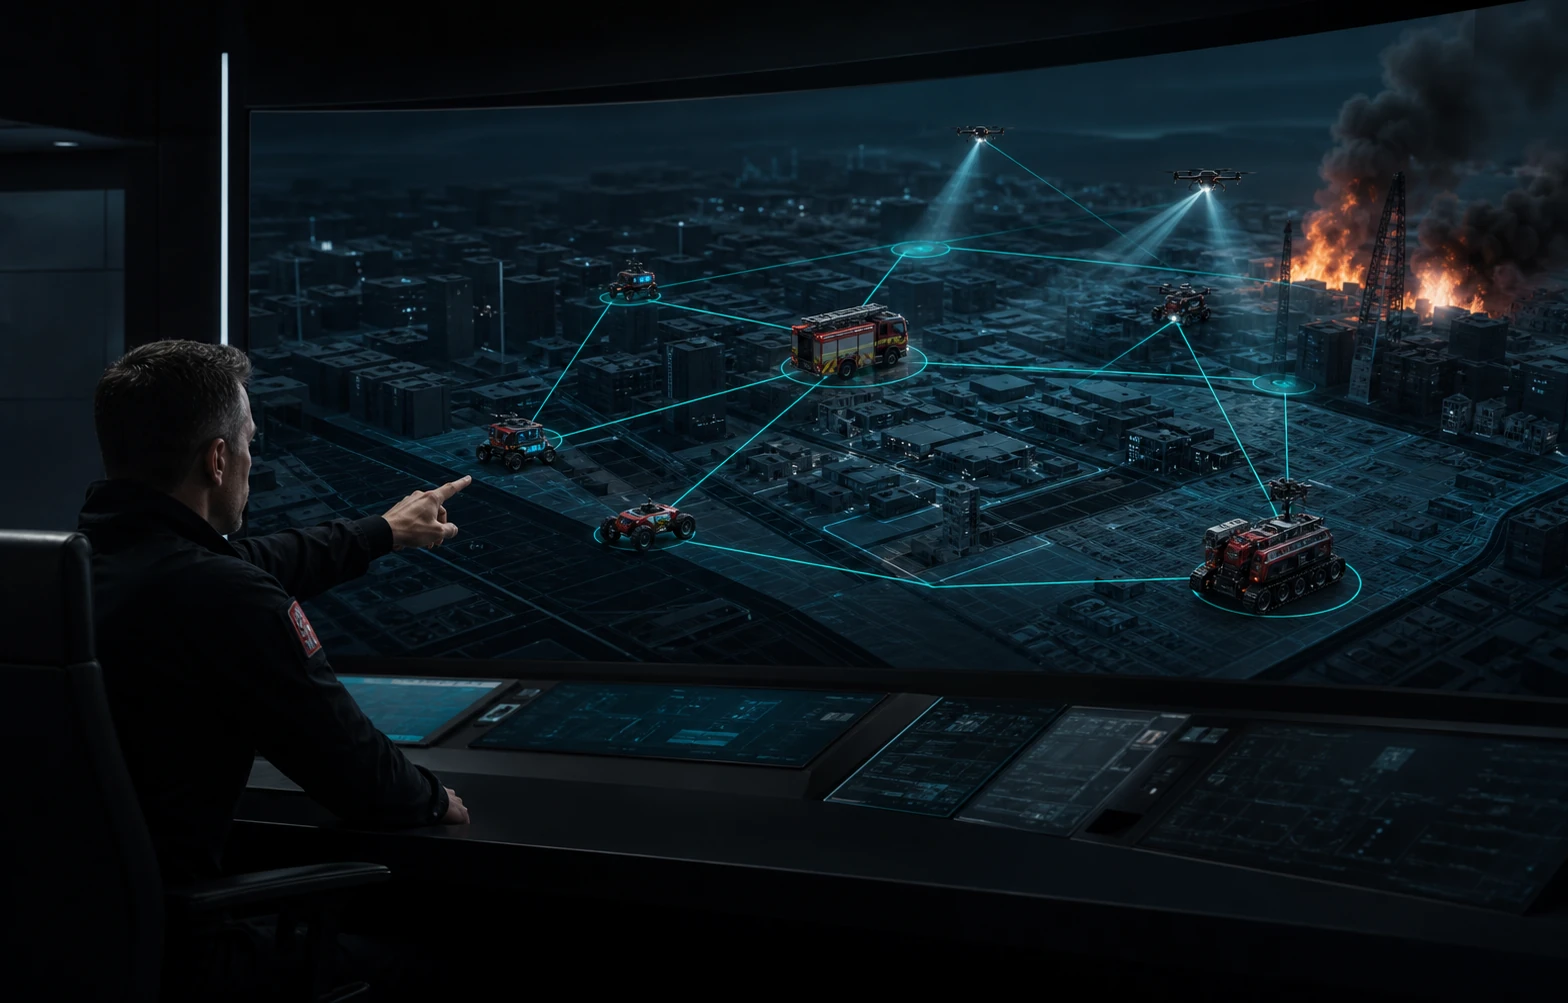
Define the area, outcome, timing and safety boundaries in mission language.
Personnel must determine which equipment is suitable for each task.
Roles are assigned using location, payload, energy and health state.
Routes for different robots require repeated coordination and adjustment.
The system generates routes, airspace relationships and coordinated timing.
Risks may only appear during execution or manual review.
Missions are rehearsed digitally and critical constraints are validated independently.
New hazards, low energy or equipment faults increase command workload.
Live state feeds continuously repair the plan within approved boundaries.
Remote-control capability degrades directly with communication quality.
Onboard intelligence continues authorized work or triggers a safe protection strategy.
AUTONOMOUS MISSION LOOP
The system keeps sensing, deciding and adapting around the mission goal, reorganizing work within approved boundaries when conditions change.
CLOUD · EDGE · INTERFACE · ALGORITHM
Cloud orchestration, edge autonomy, 3D interaction and algorithmic simulation create an intelligent command system spanning the full mission lifecycle.
Unifies mission understanding, intelligent teaming, resource scheduling and execution monitoring.
Maintains execution, command arbitration and safety protection in weak or disconnected networks.
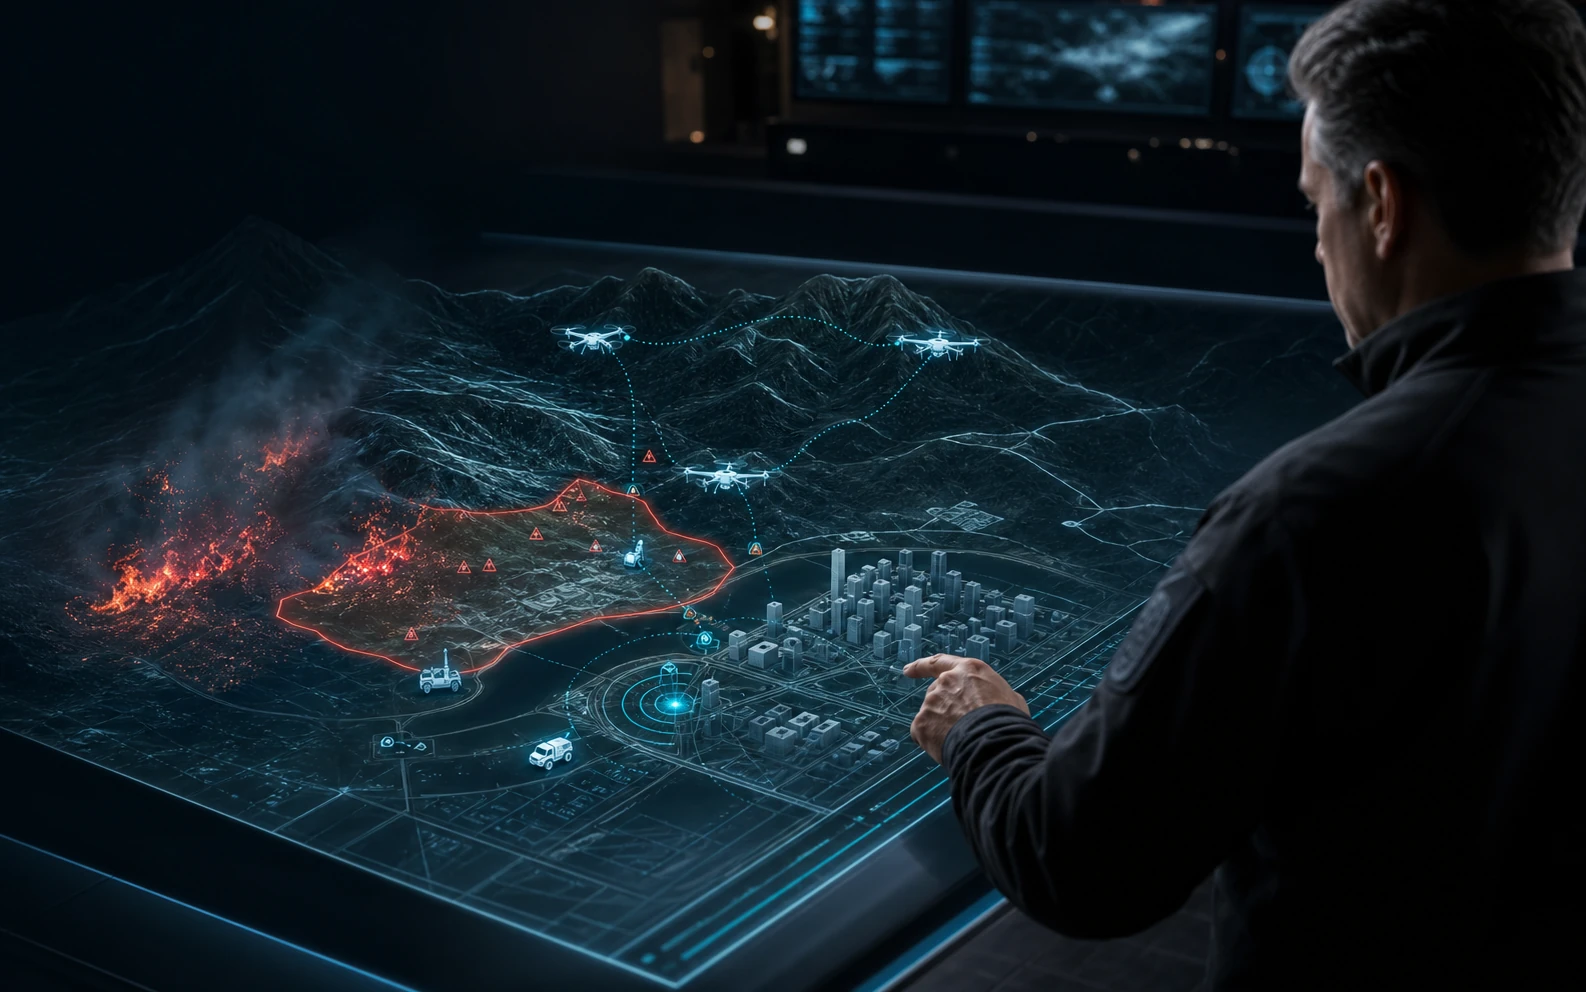
Combines 2D and 3D awareness with natural-language command and human takeover.
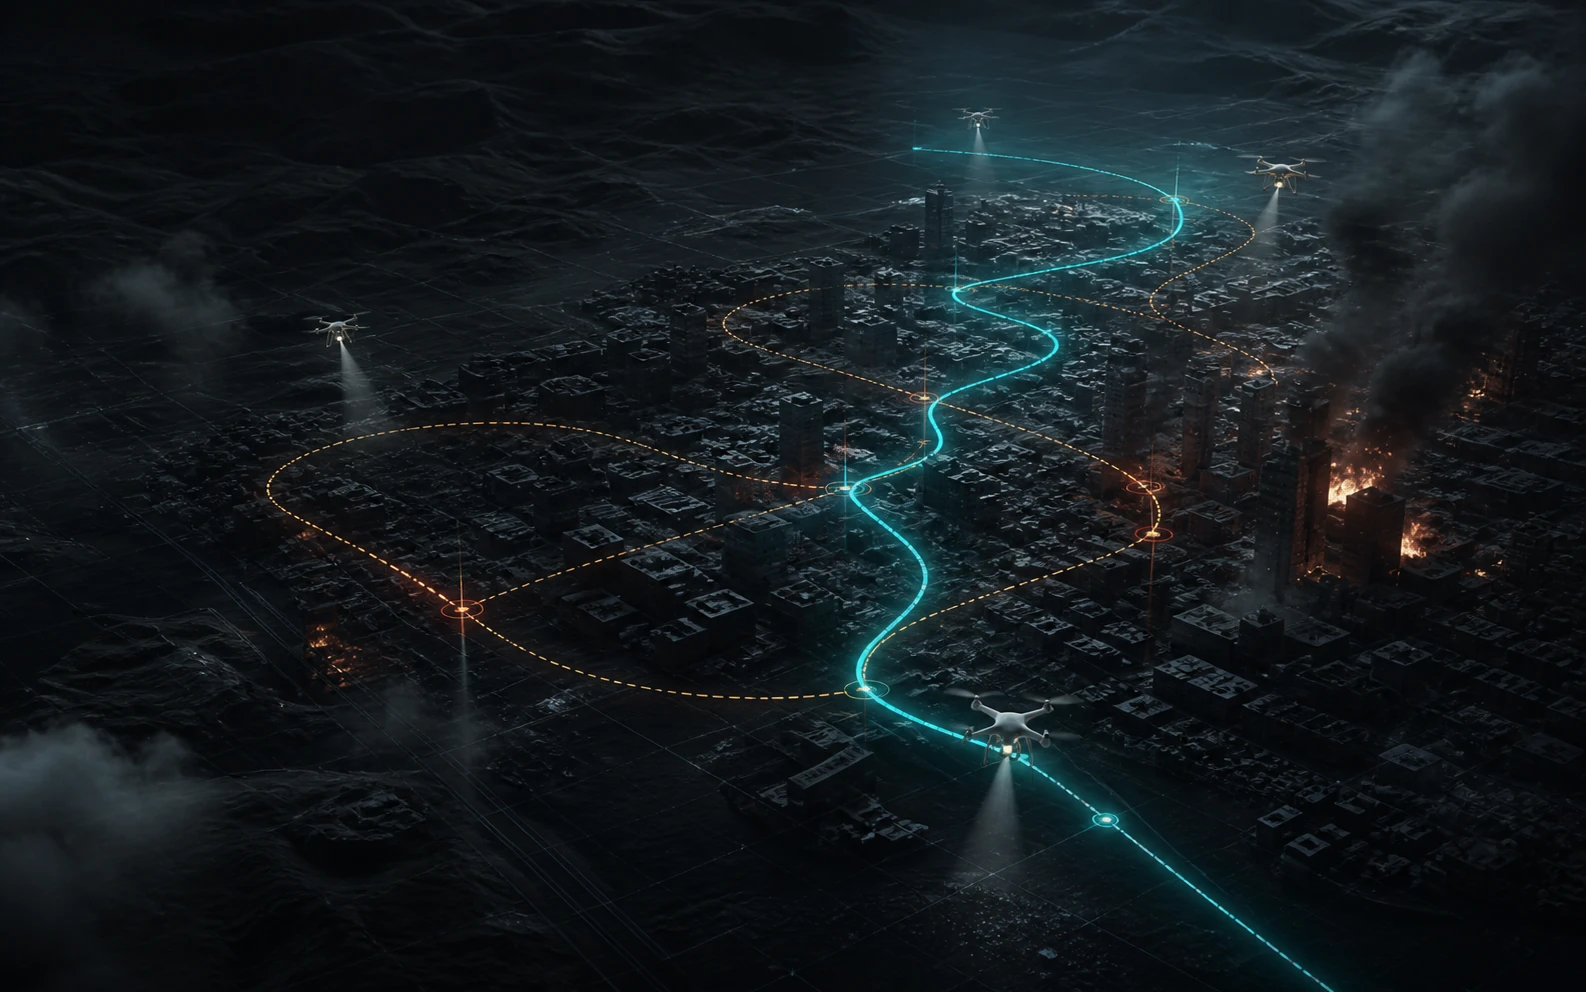
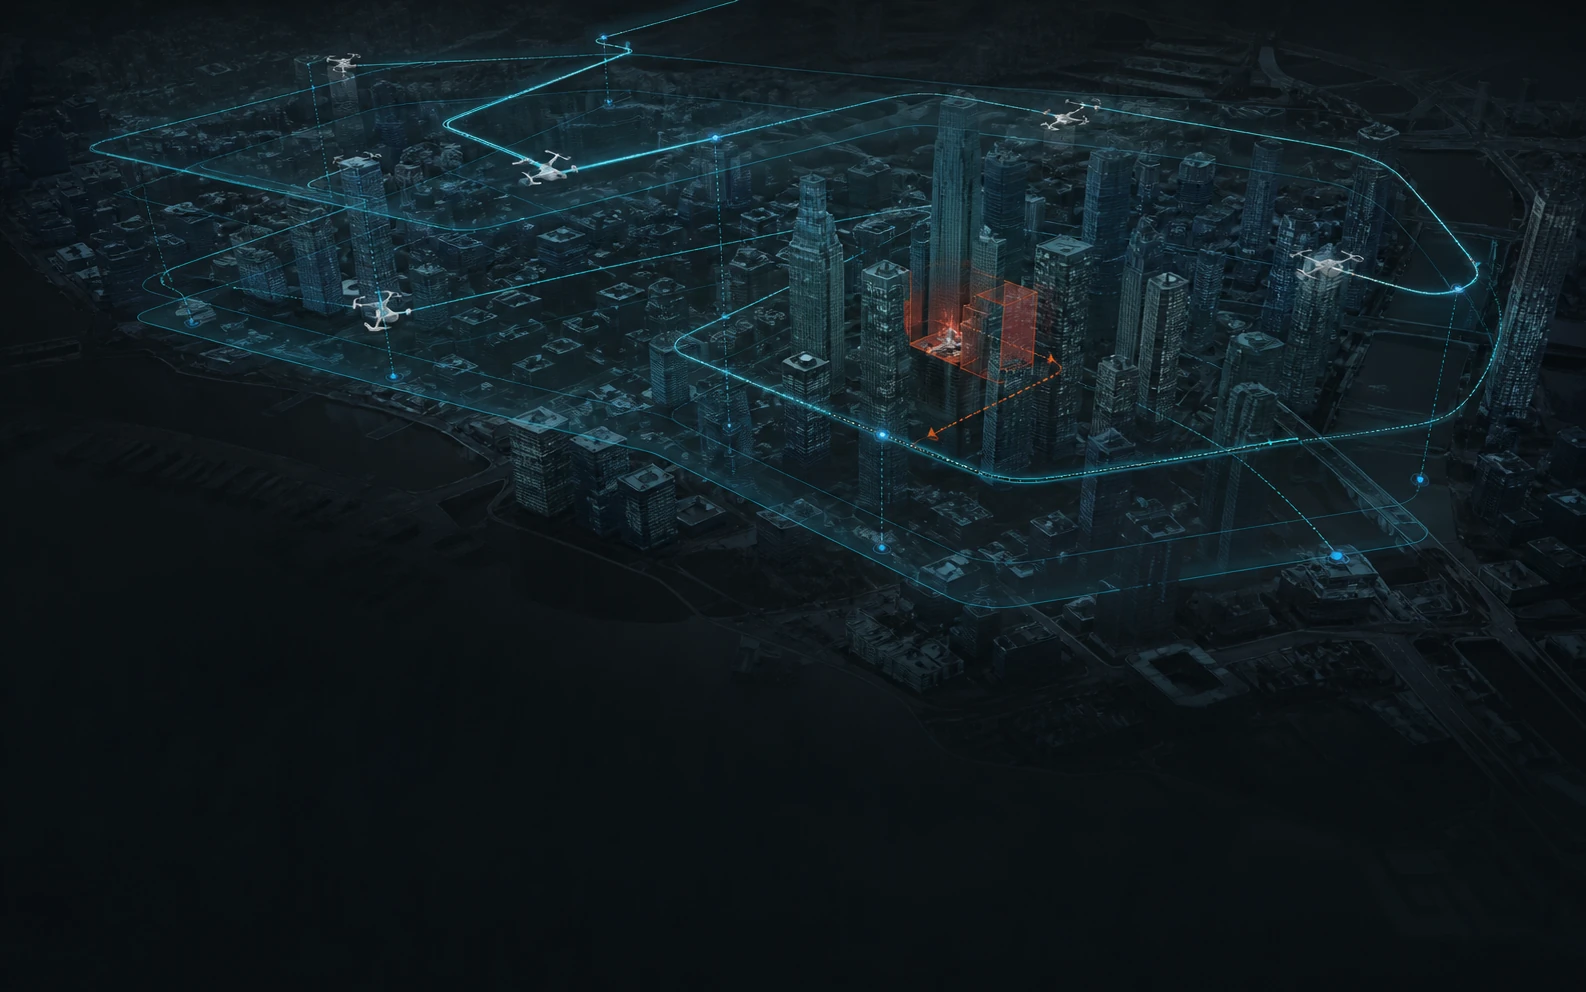
Plans routes, resolves conflicts and rehearses missions in a digital twin.
CORE CAPABILITIES
 01
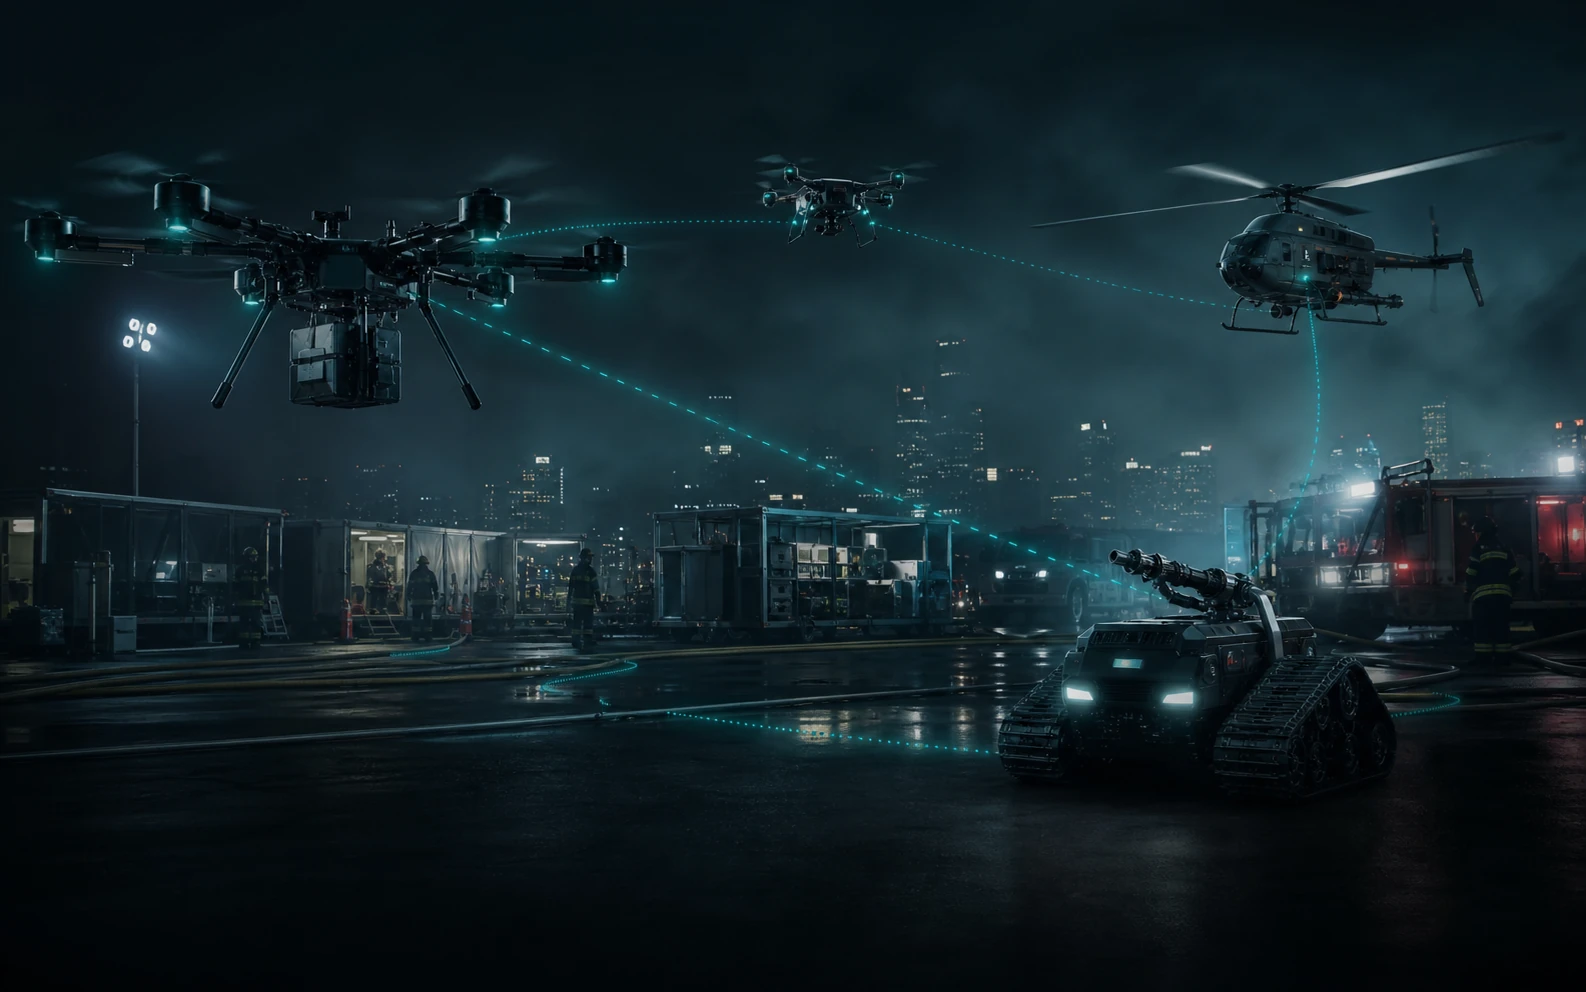
Describe goals, areas and constraints in mission language; the system turns intent into an executable plan.
 02
Assign the right roles using location, payload, energy and health across different robots.
 03
Plan routes, airspace and collaboration in one operational picture.
 04
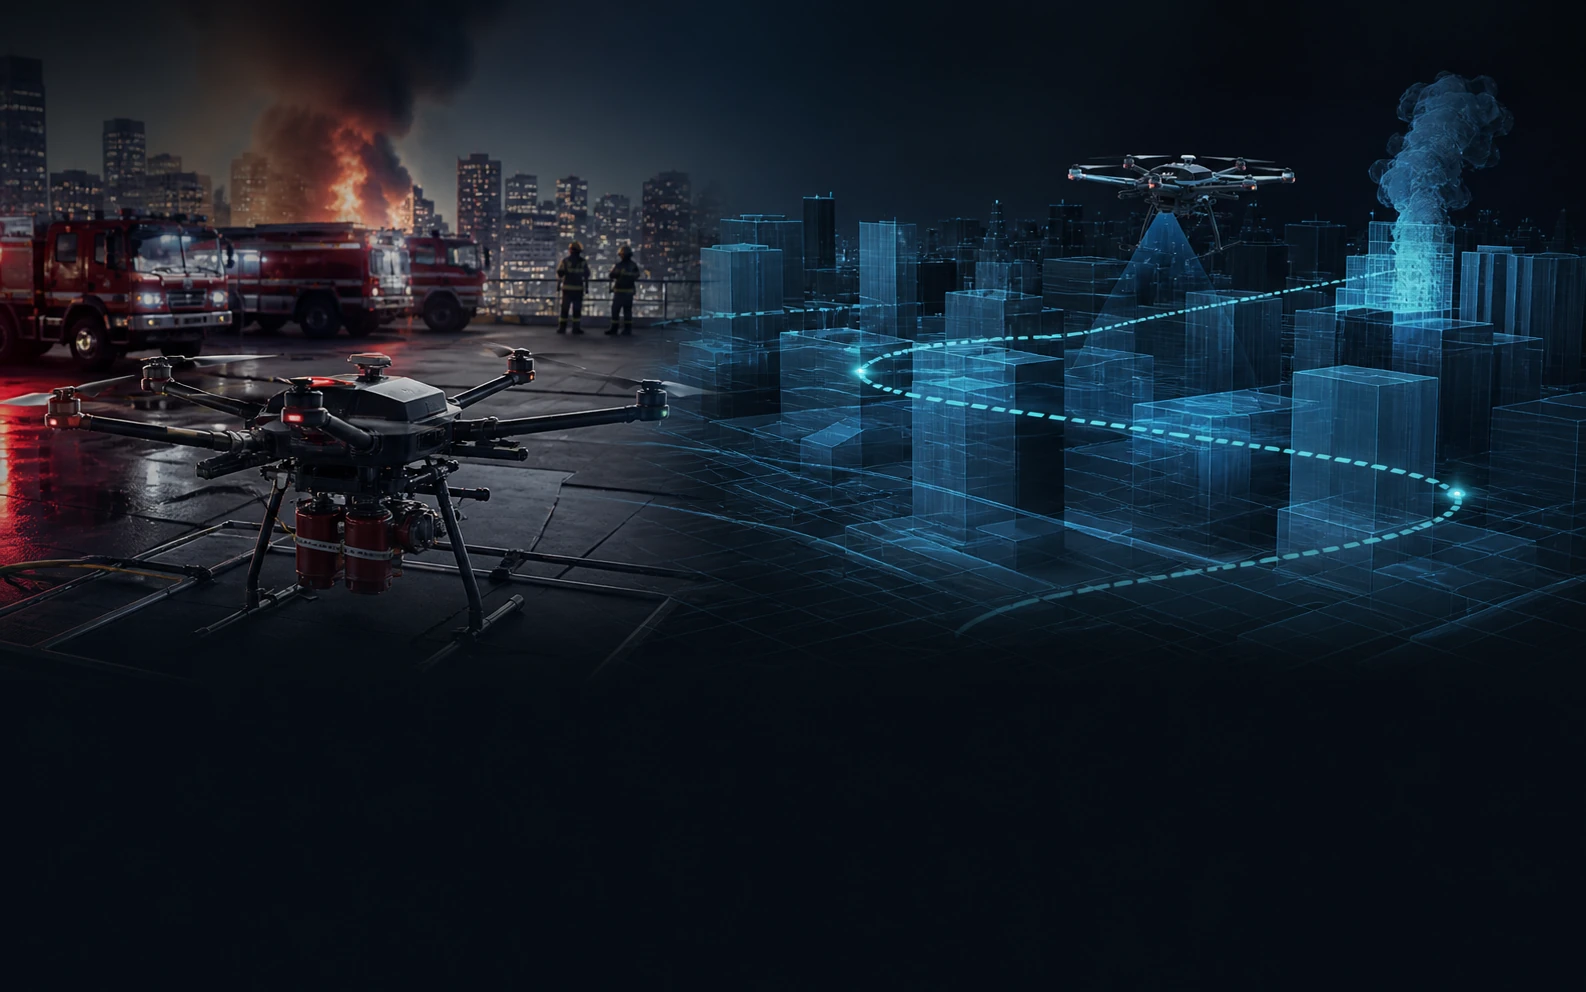
Rehearse plans in a virtual environment to identify conflicts and risk before execution.
 05
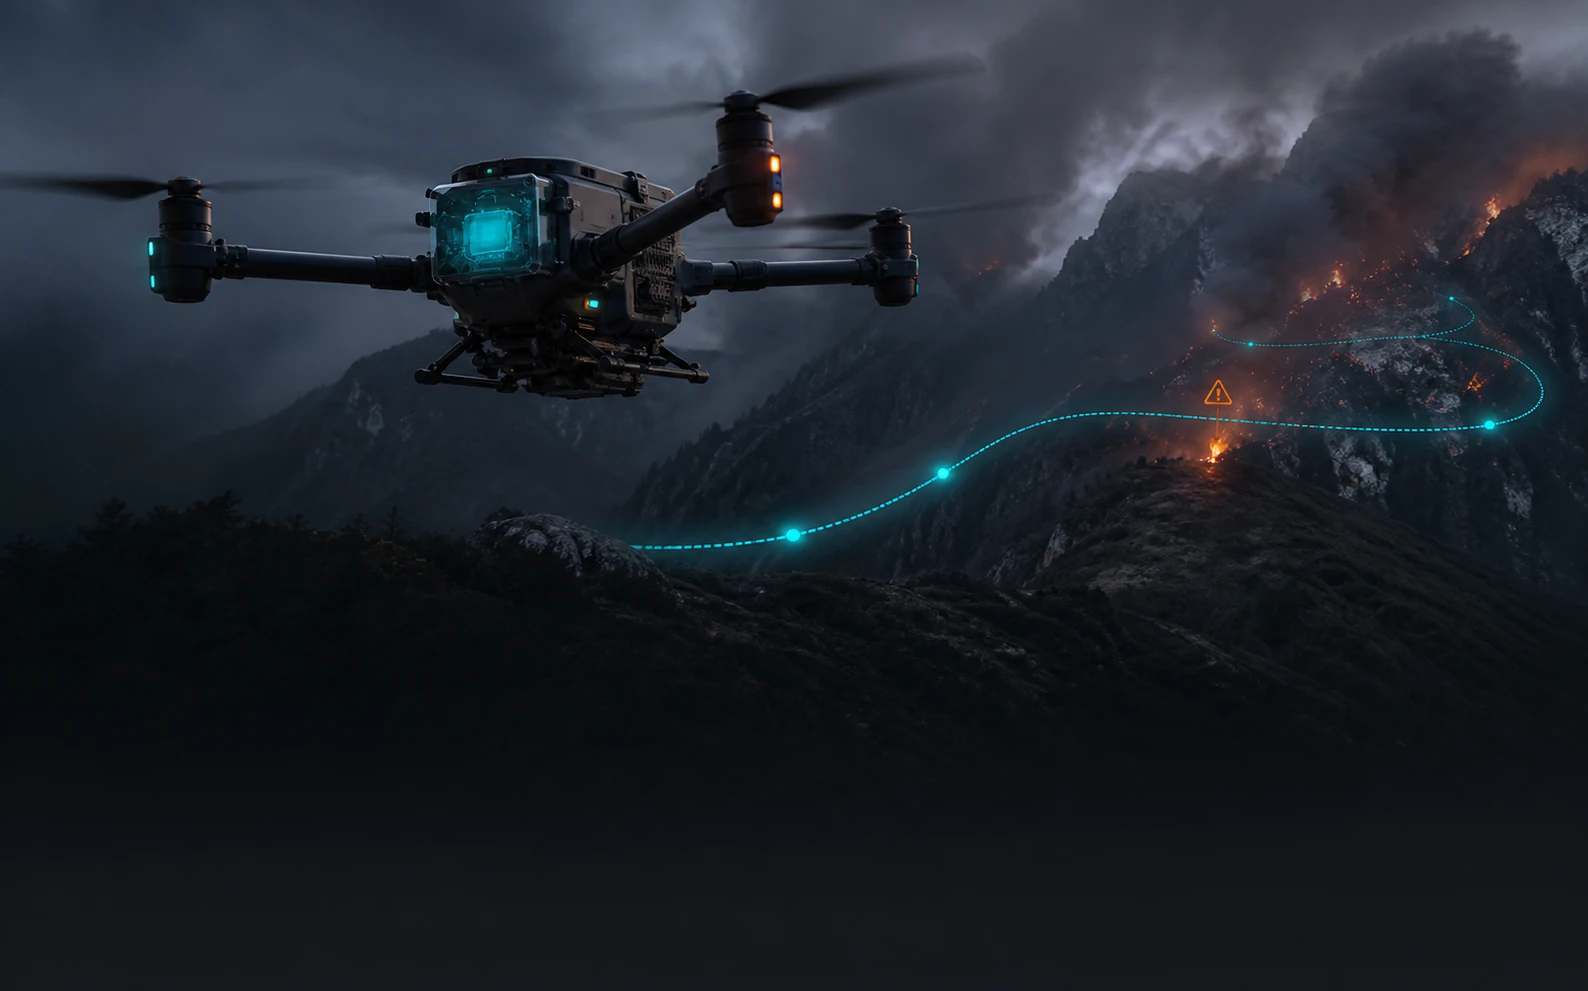
Edge intelligence sustains the mission while independent safety logic can reject unsafe actions.
PLATFORM IN ACTION
Situation awareness, route generation, airspace planning and closed-loop monitoring come together in one command interface.
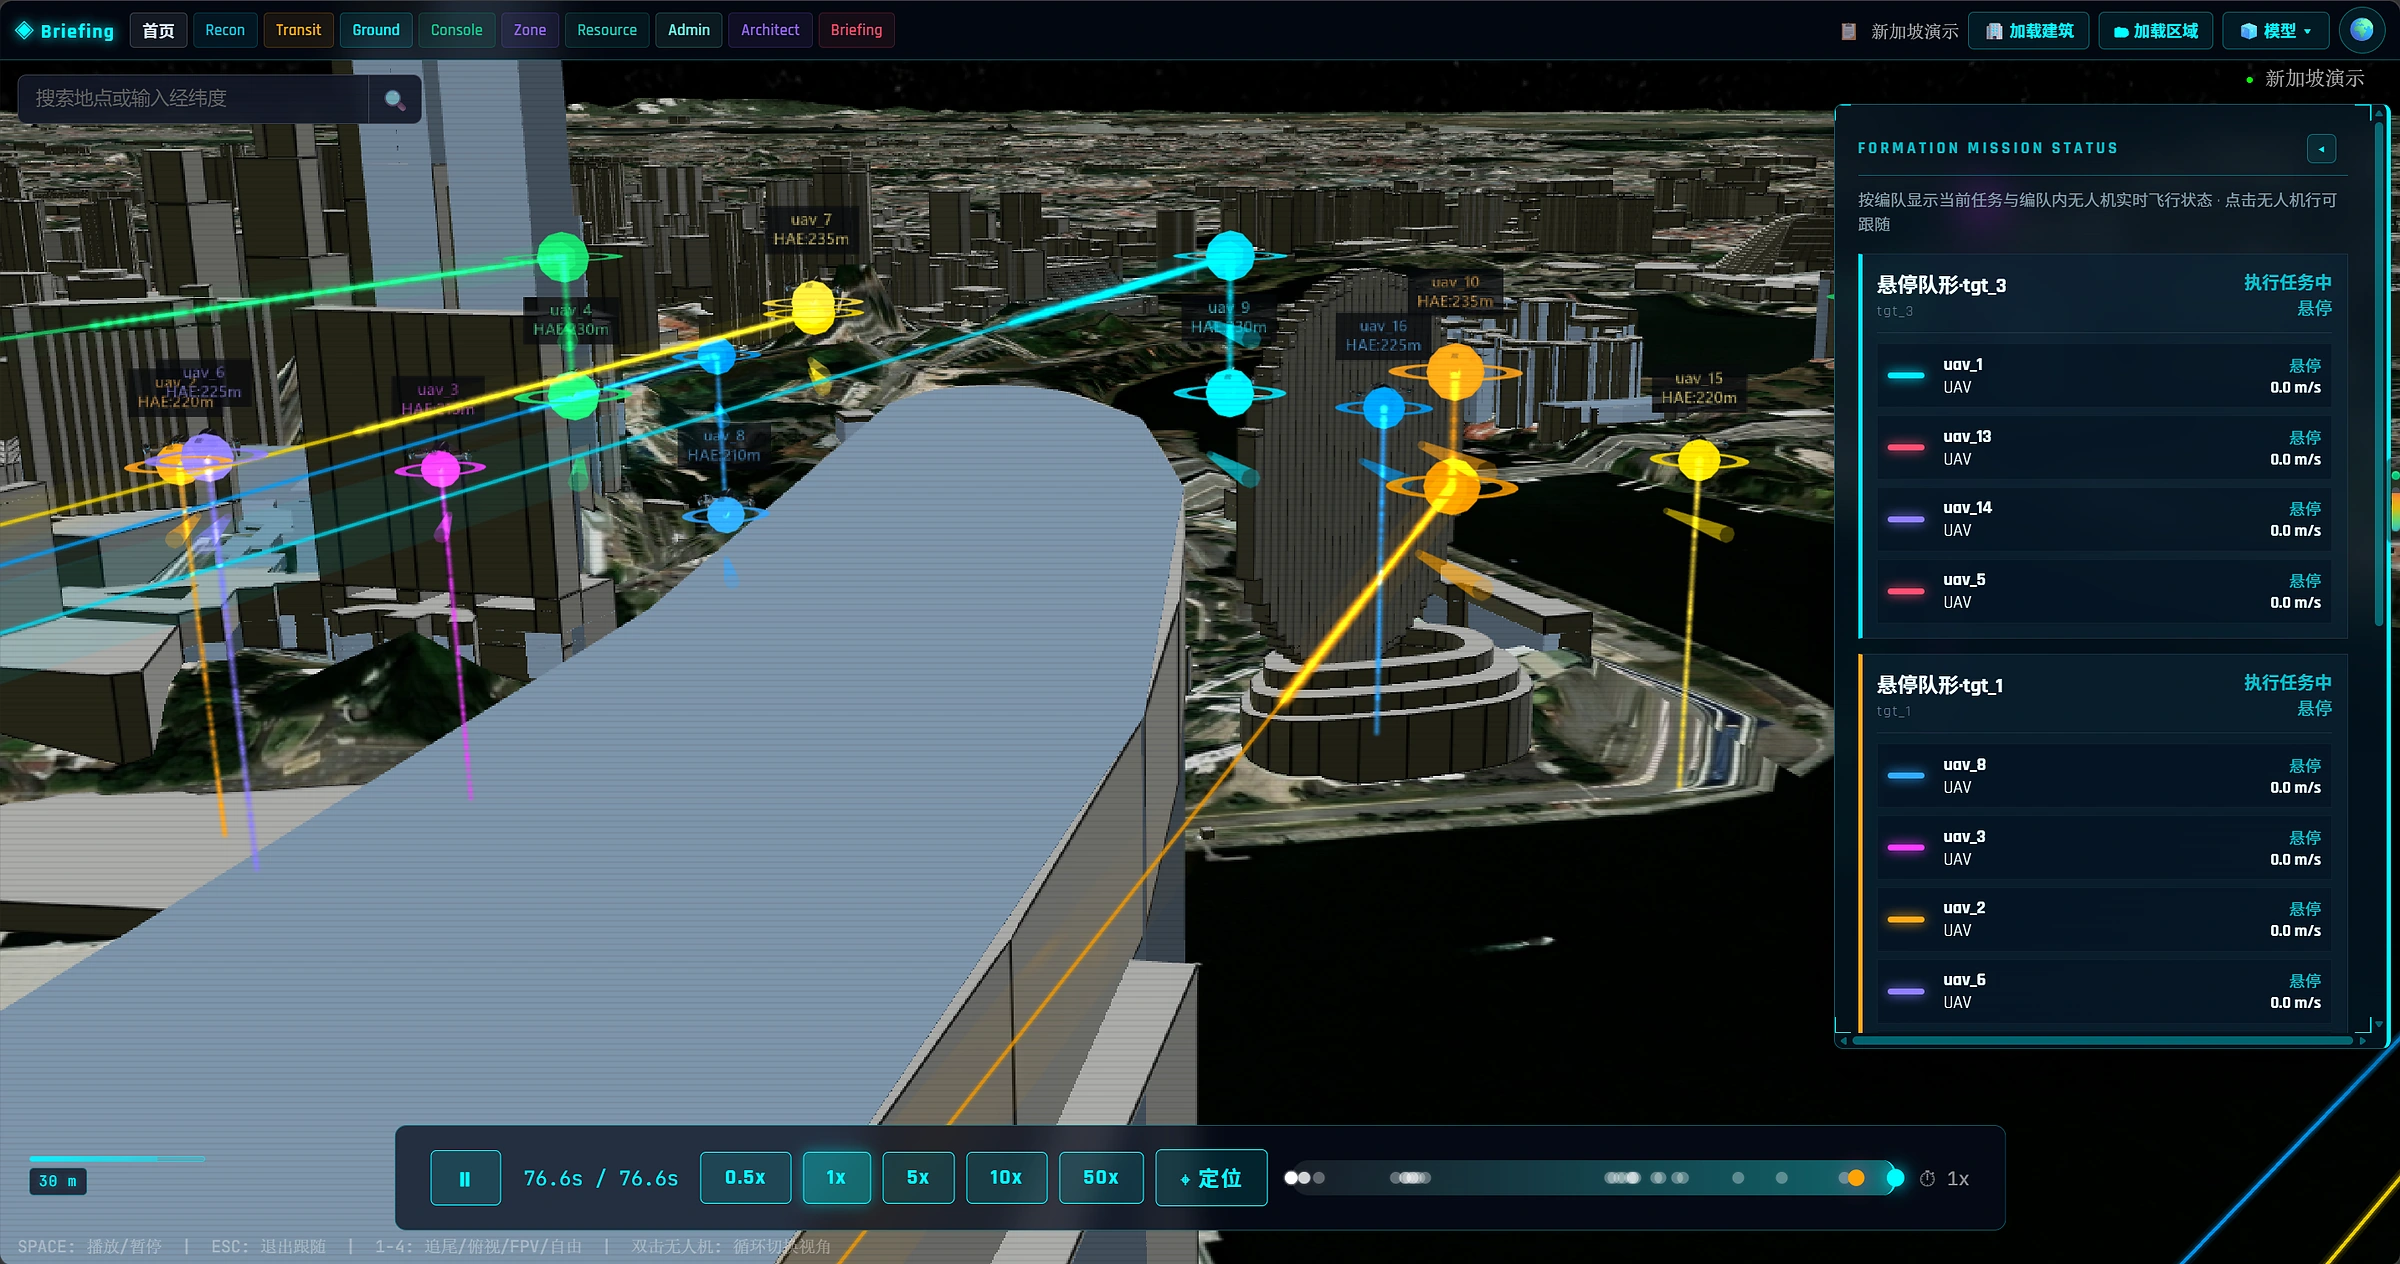
View missions, robots and the operating environment on one map.
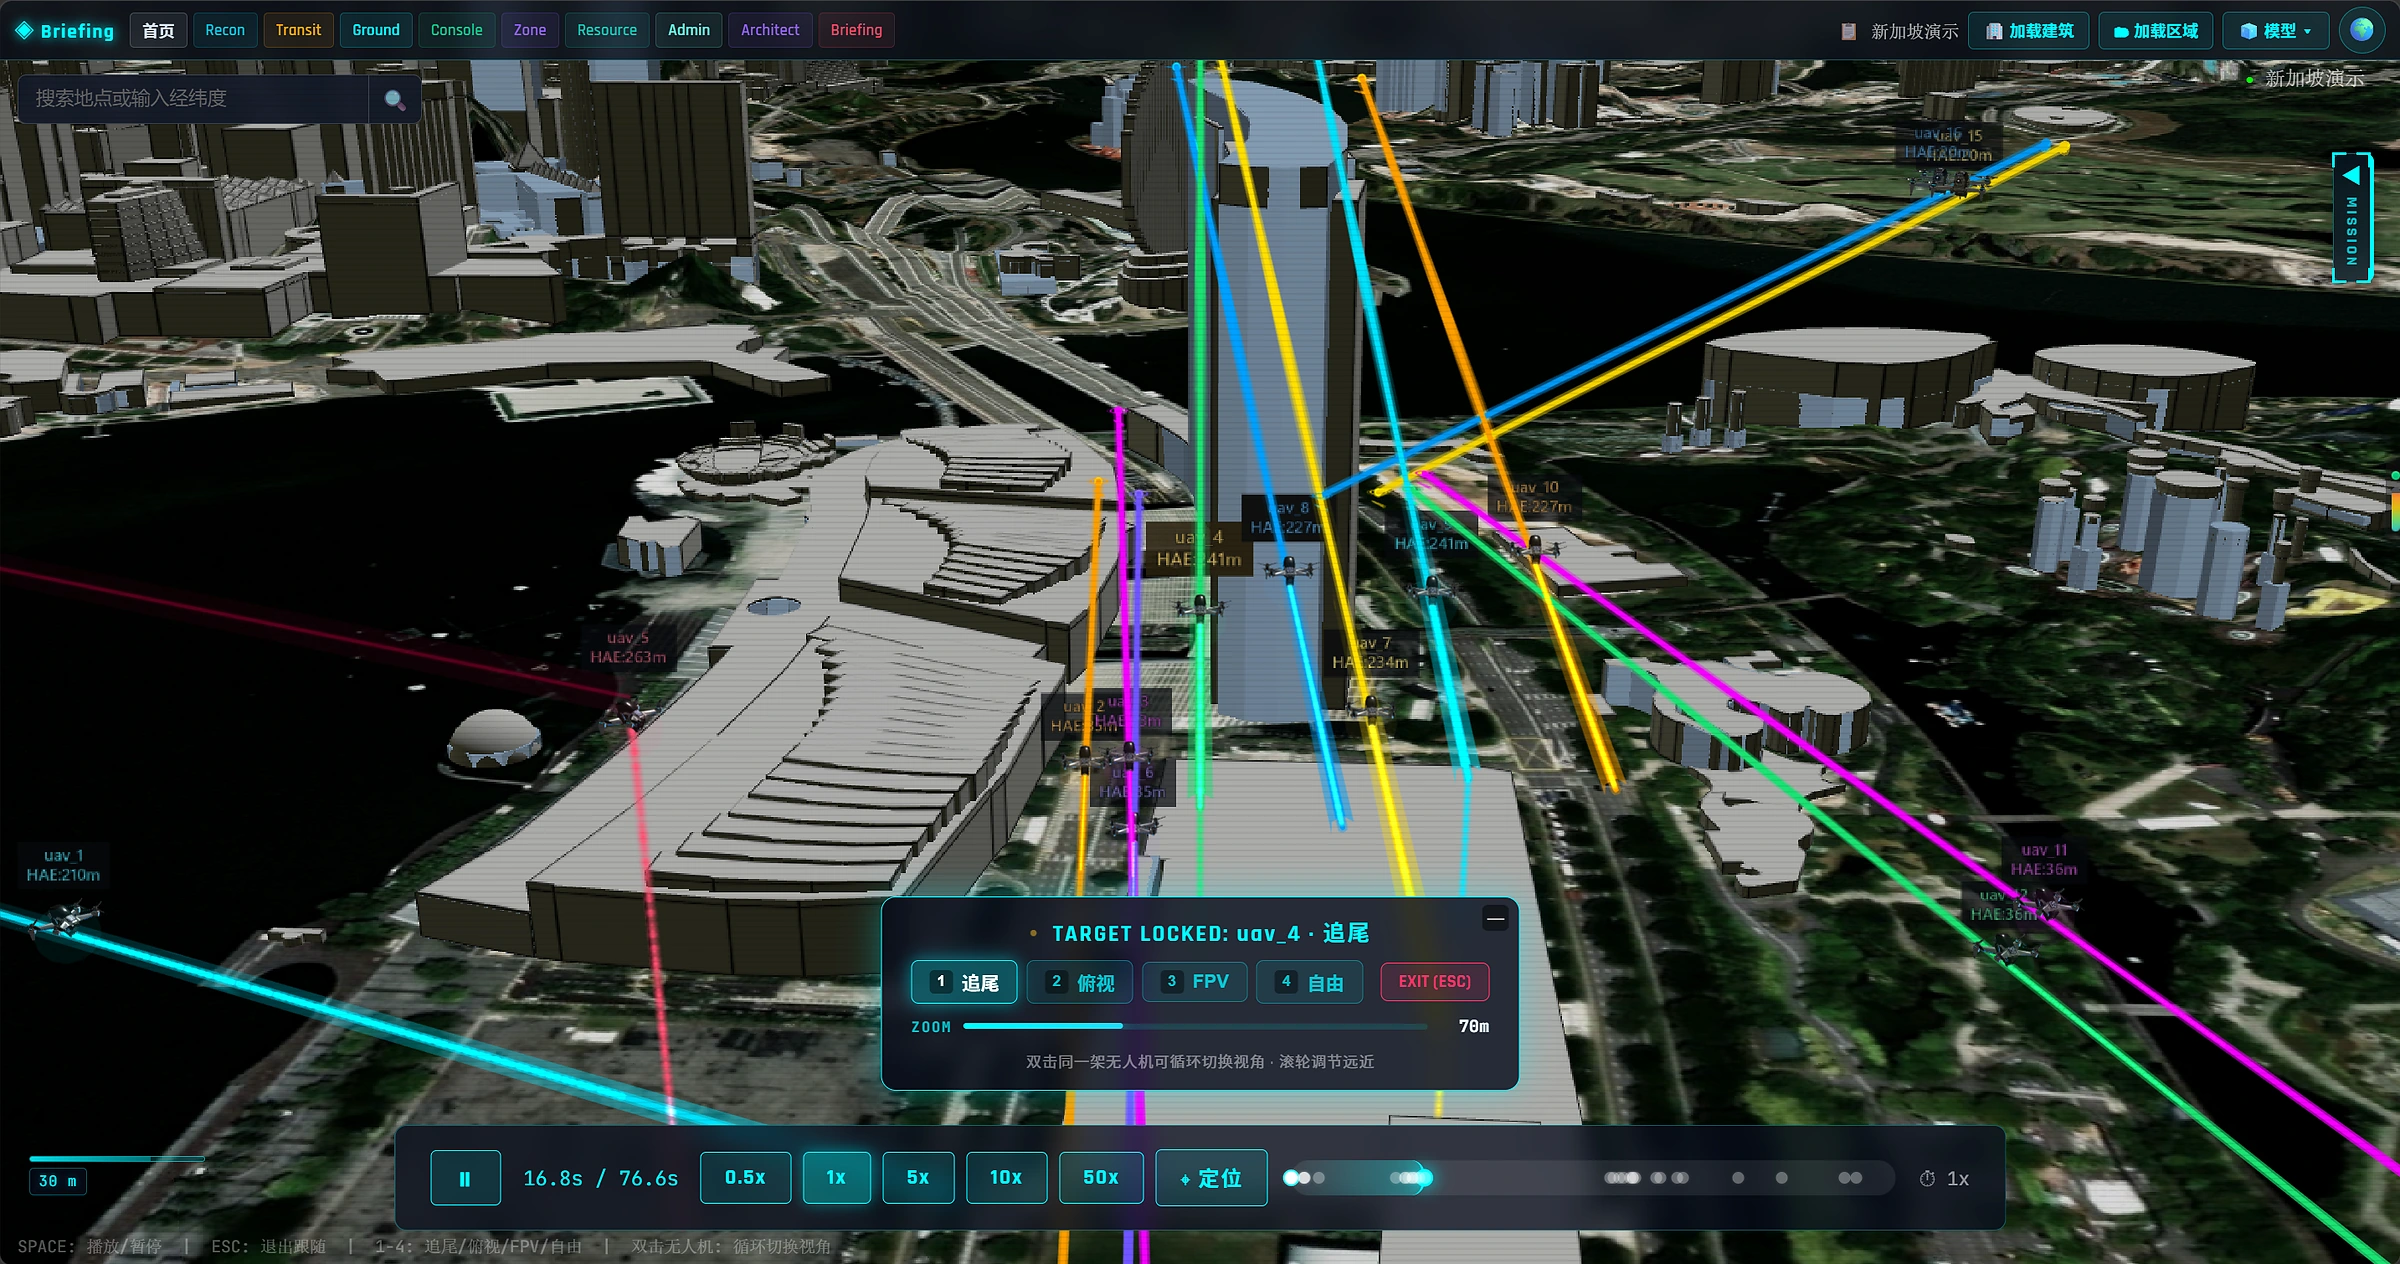
Turn intent into robot teams and executable steps.
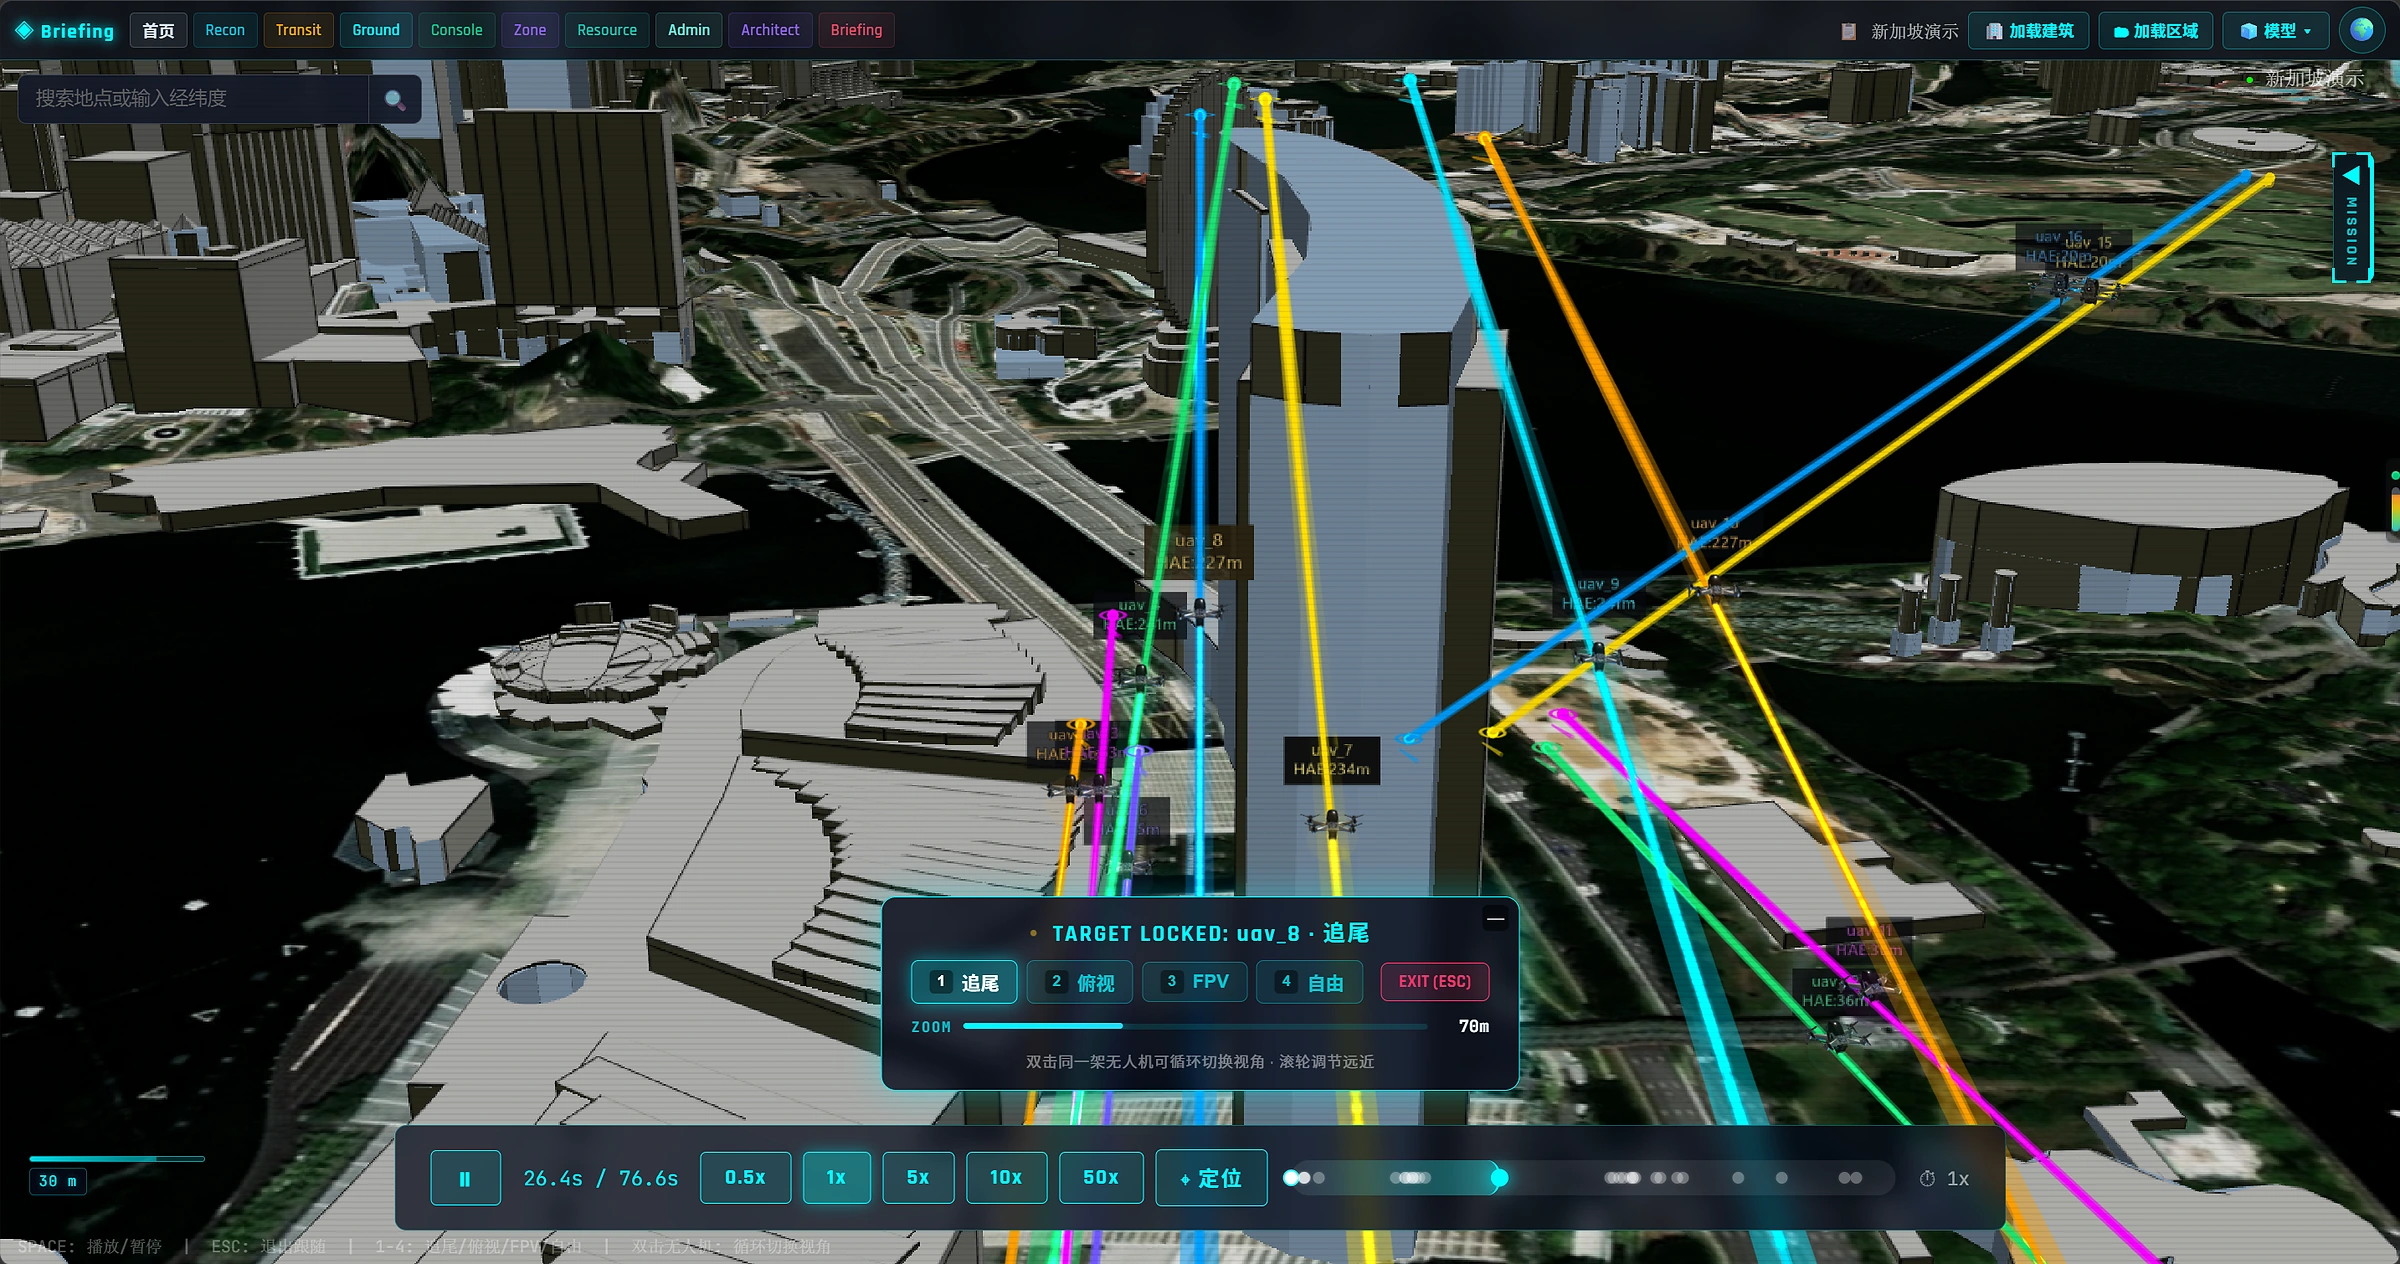
Validate routes and key actions before execution.
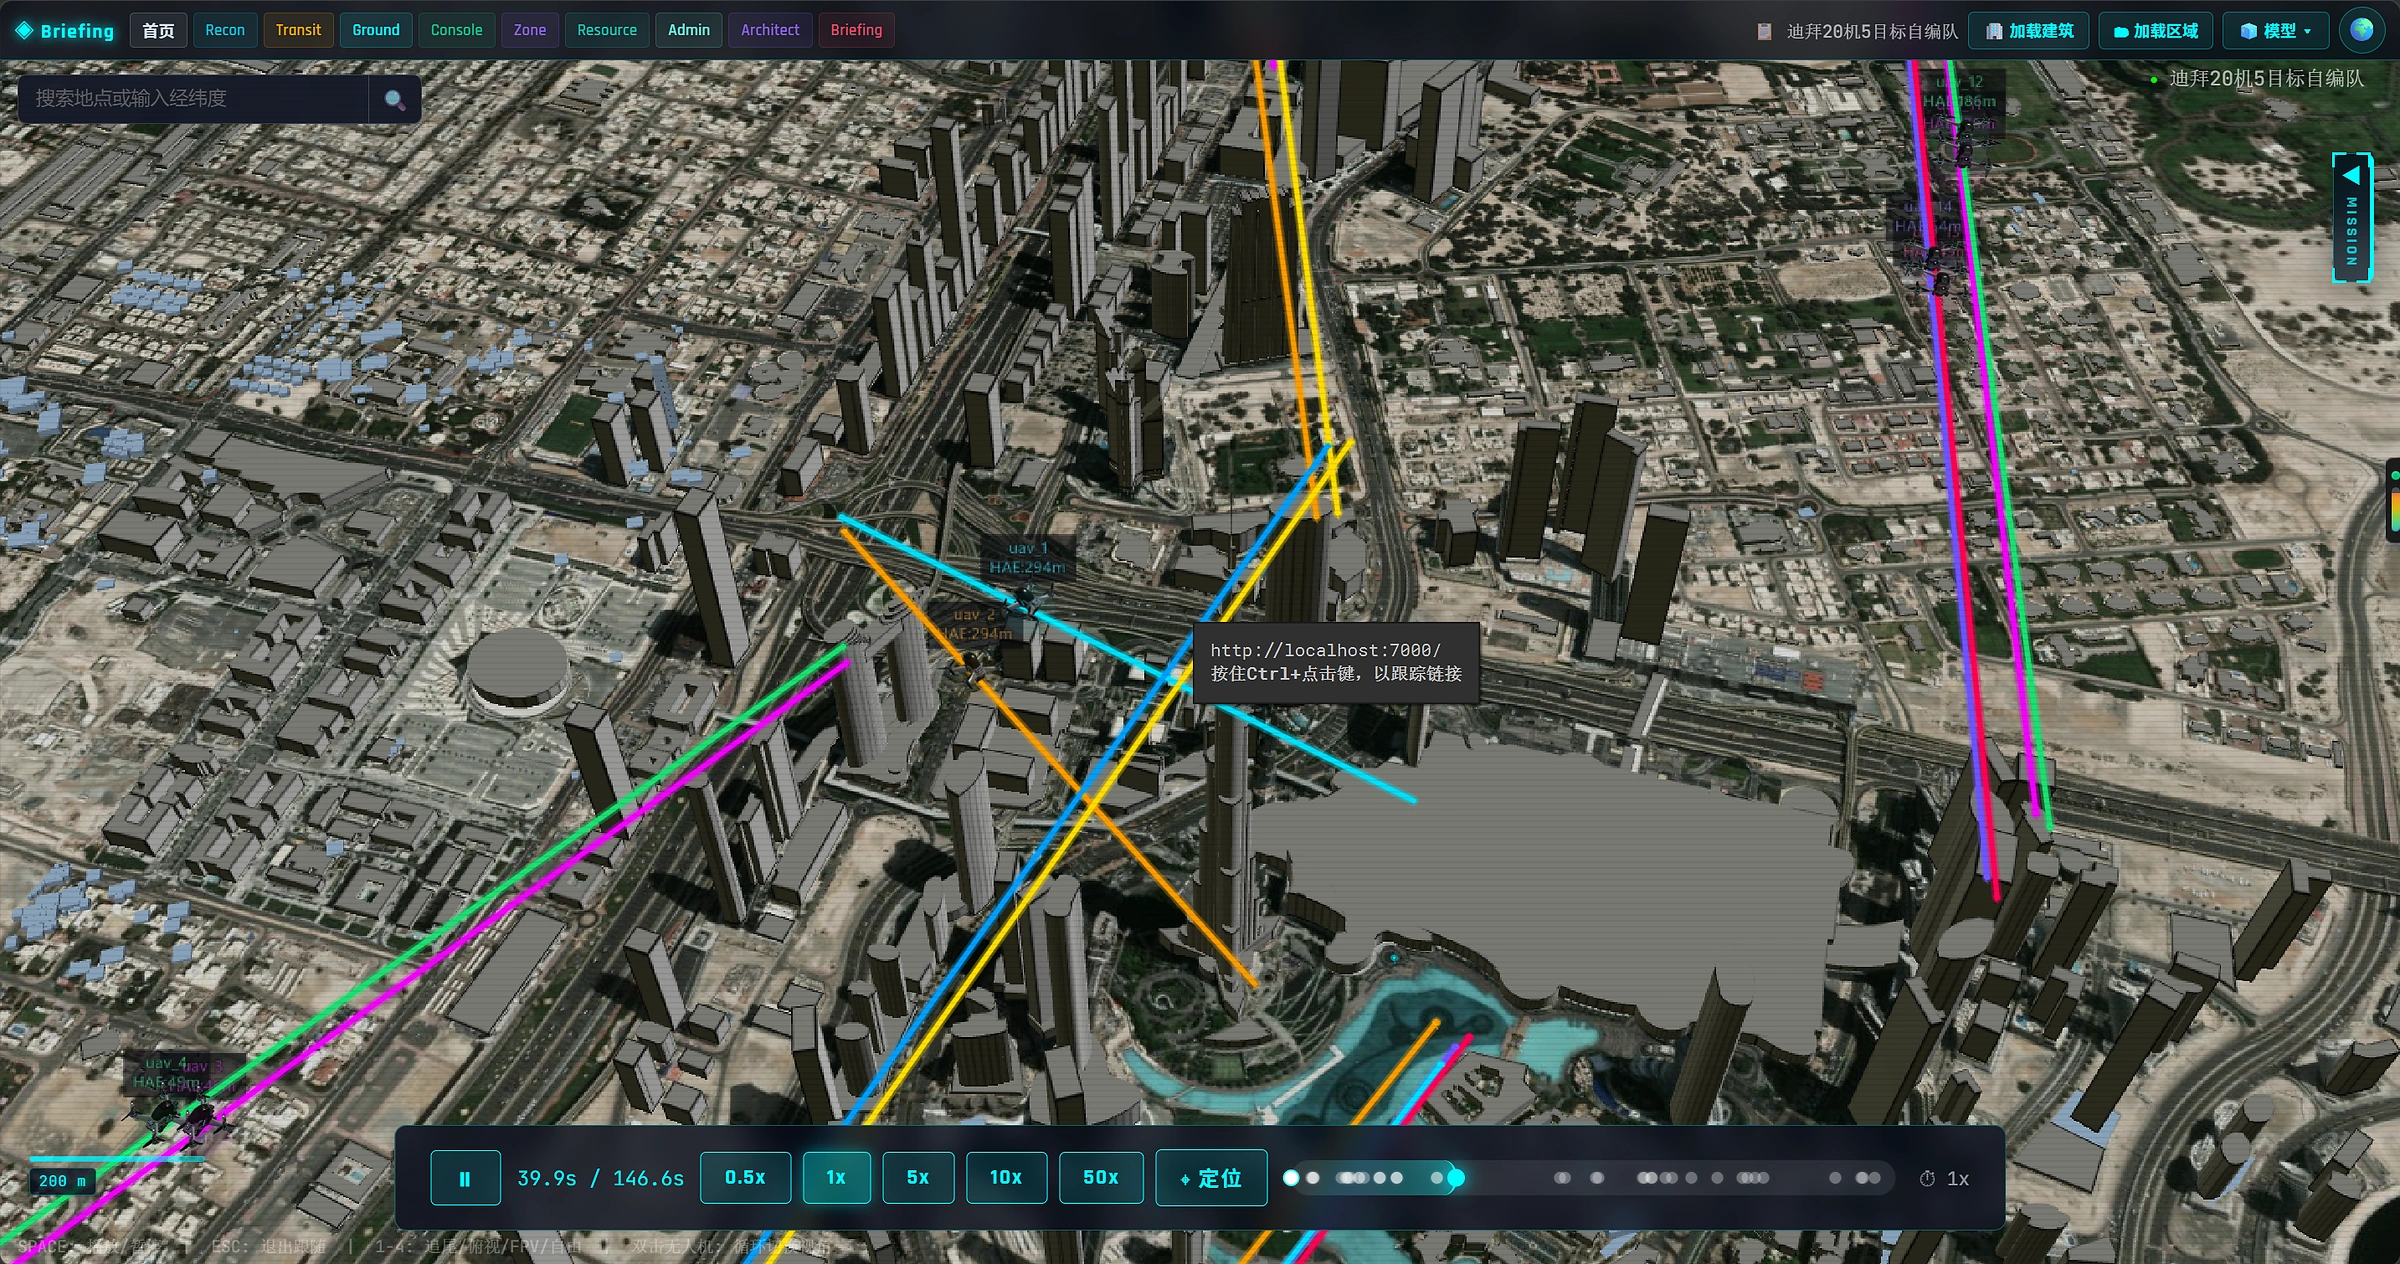
Organize multi-robot collaboration and resolve potential conflicts.
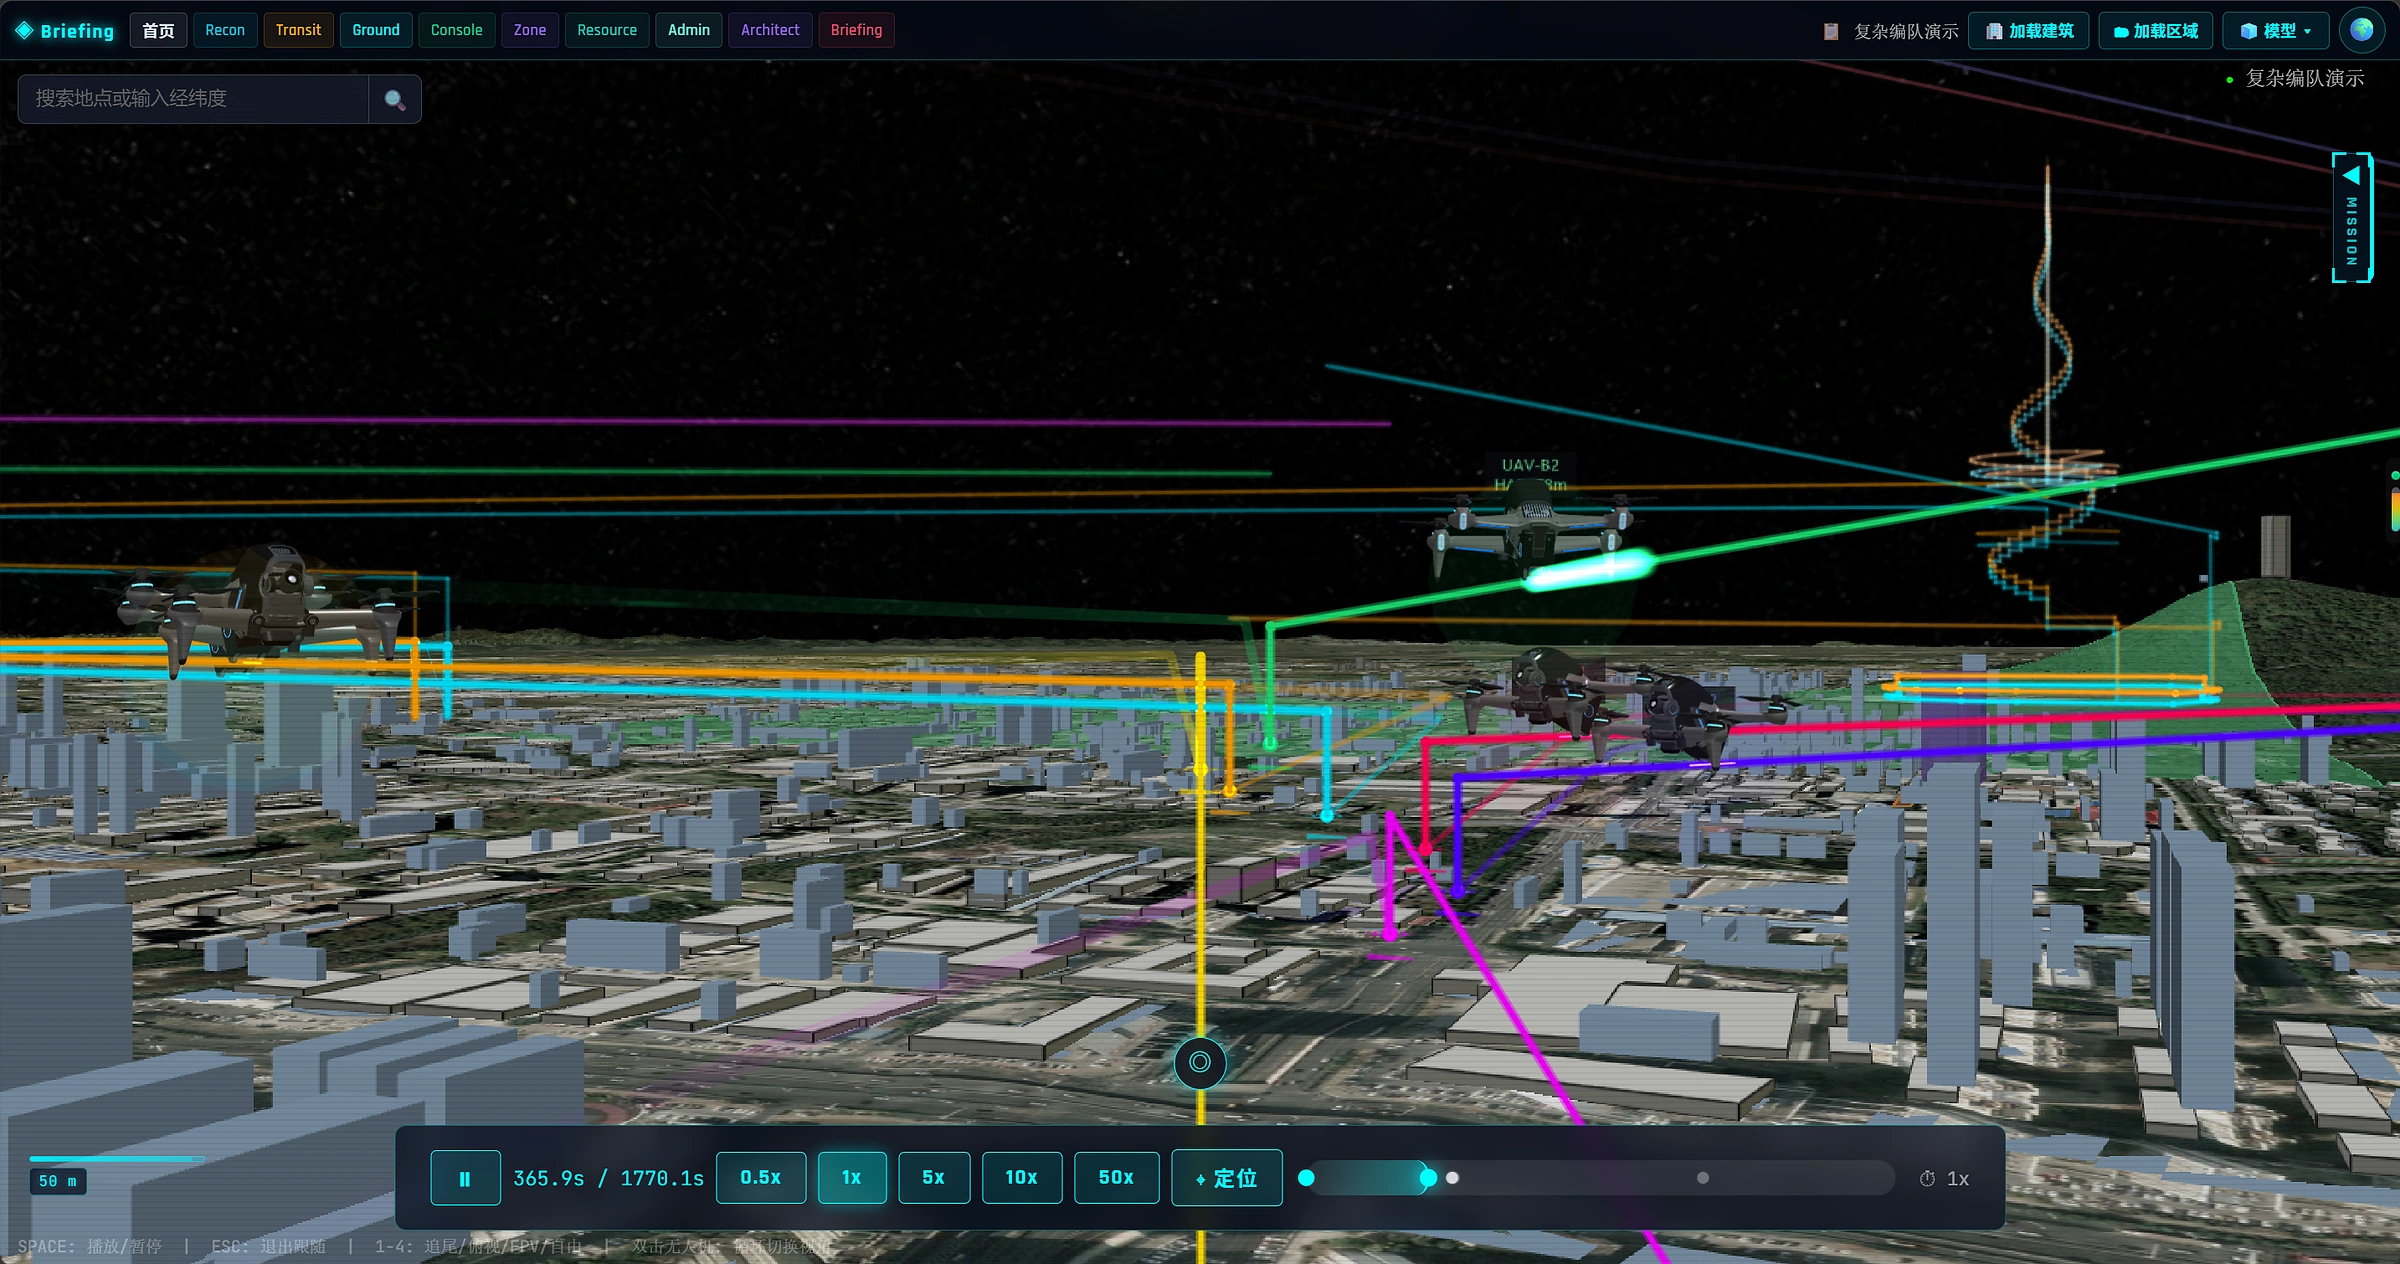
Receive live status and adapt the plan as conditions change.
HUMAN-CENTERED AUTONOMY
Autonomy never means losing control. Critical actions require authorization, unsafe plans can be vetoed, and commanders can pause, take over, return or stop a mission at any time.
01Human authorization for critical missions
02Independent safety validation
03Pause and take over at any time
PLATFORM DEMO
This first edit shows how the platform understands a mission, organizes robots, plans action and closes the execution loop.
G-MATRIX
Request a platform demo and see how G-Matrix can organize your unmanned equipment around the mission.
Request a Platform Demo